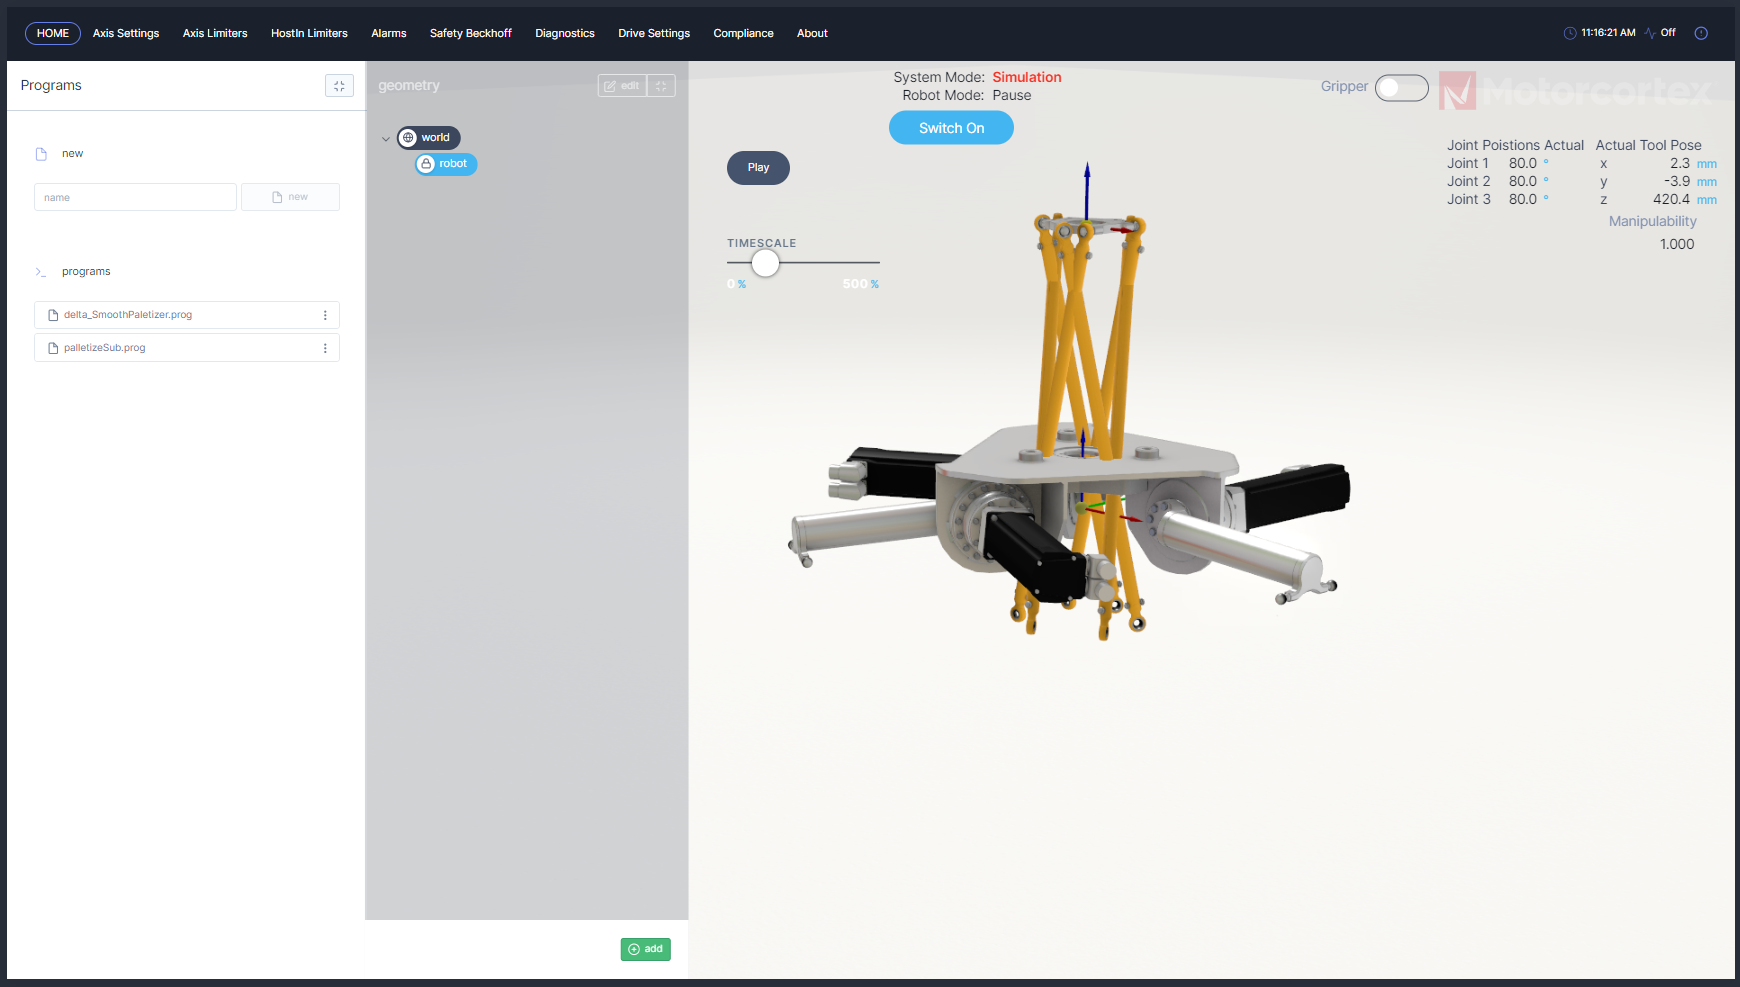
SamW I'm running Motorcortex Robot App - Delta - 2024.01 in version 3.9.0. The procedure to reproduce: Robot can be in any mode (any axis or all in production or simulation or a combination). When GUI is launched, go to Axis Settings. Change n Loadside to 35 and then click Reference -> Save Settings. Go to GUI and there should be no visual changes. Go back to Axis Settings and change n Loadside to 1. Click Reference -> Save Settings. The robot looks like the image below. Even when everything is referenced properly, the solver will produce the tooltip in positive Z when this in reality is not possible. To fix this, the config/GUI must be redeployed.
SamW This not only happens while changing the gearbox ratio. This can happen while referencing the axis as well.